|
Nidhya Shivakumar I am an incoming M.S. student at Stanford University studying Computer Science. I graduated from UC Berkeley with a B.S. in Electrical Engineering and Computer Science in 2026. I work in Professor Ken Goldberg's AUTOLab on several projects related to robotics and computer vision. This summer, I am working at Google Labs on their autonomous coding agent, Jules. I previously worked at Google for two summers in 2024 and 2025 on the Shopping Ads Infrastructure team and Youtube's Trust & Safety team, respectively. Email / GitHub / Google Scholar / CV / LinkedIn |
|
Research |
|
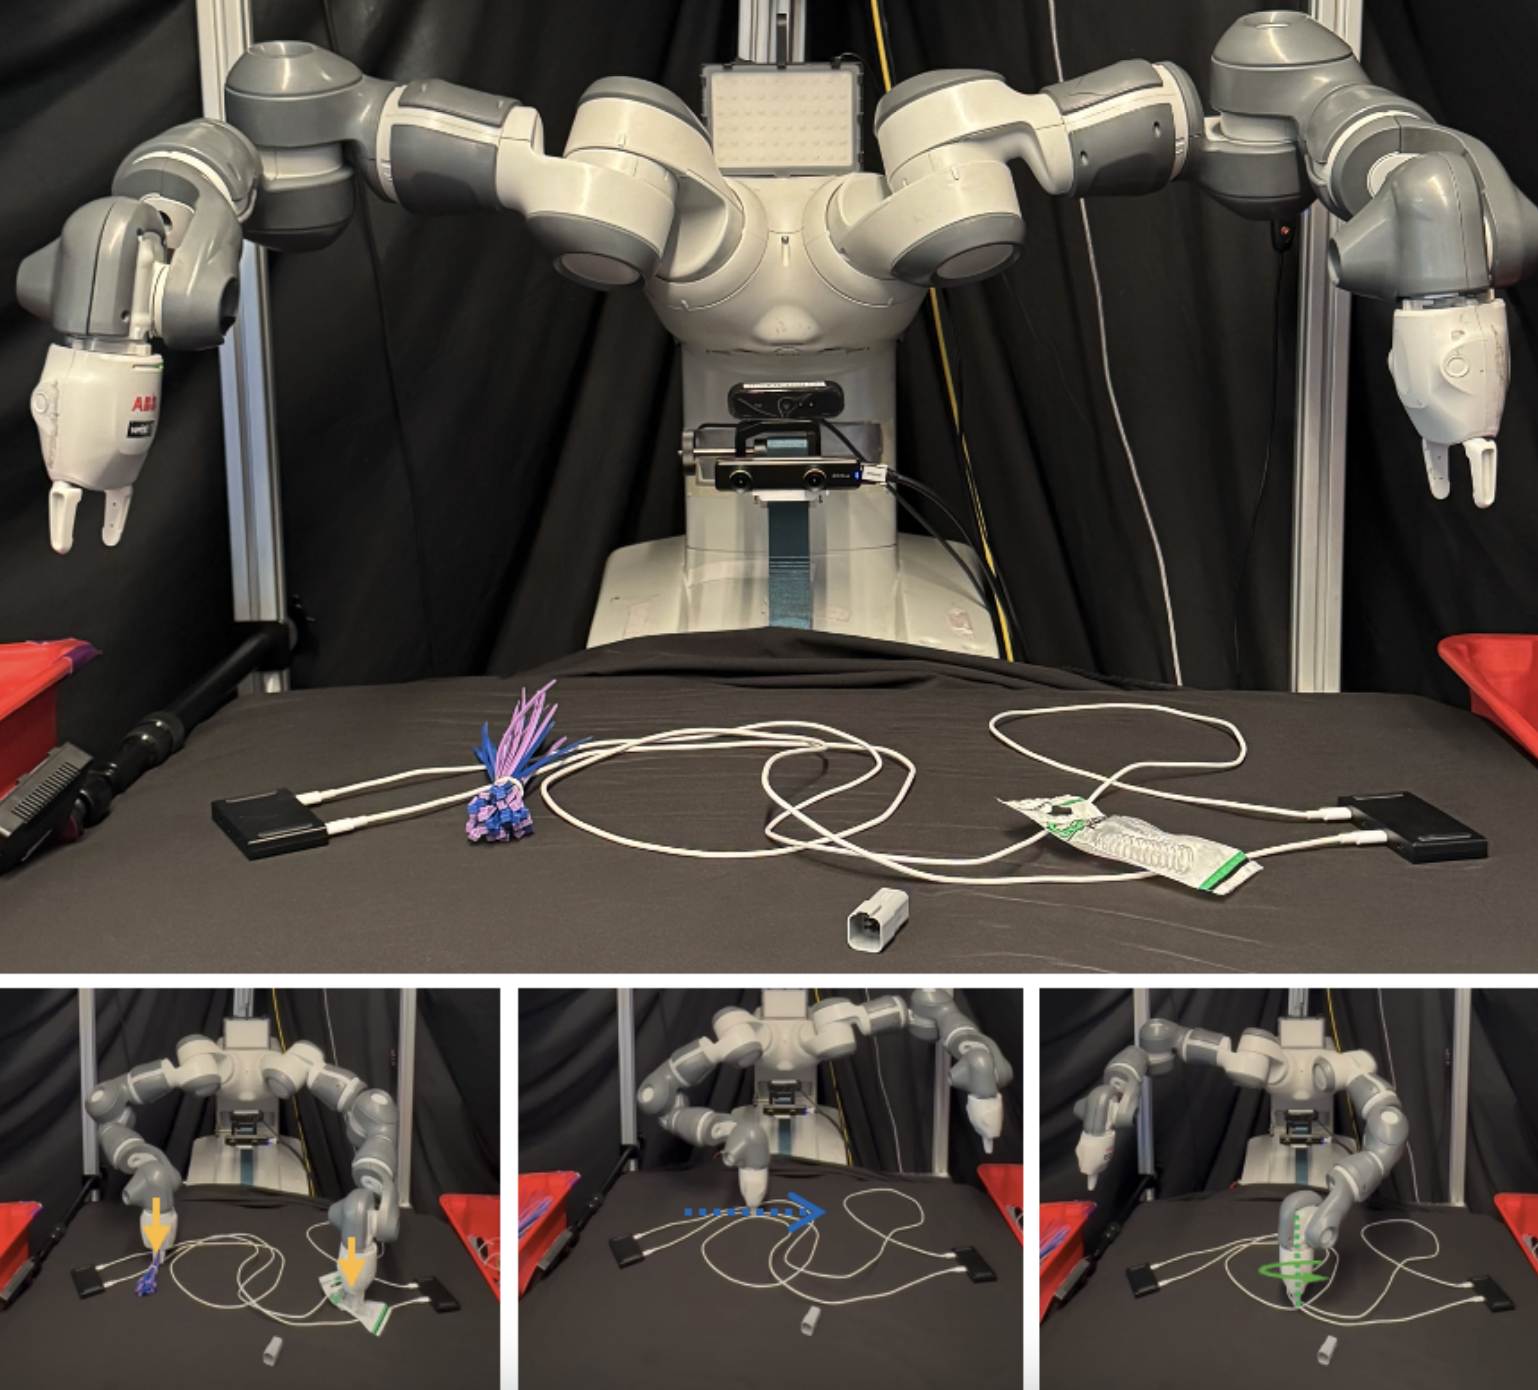
HANDLOOM 3.0: Interactive Bi-Directional Cable Tracing Amid Clutter
Justin Yu*, Nidhya Shivakumar*, Veena Sumedh*, Josh Zhang, Ethan Ransing, Osher Azulay, Ken Goldberg ICRA 2025 Deformable Objects Workshop, 2025 *Equal contribution Interactive bi-directional cable tracing system for robotic manipulation in cluttered environments. |
|
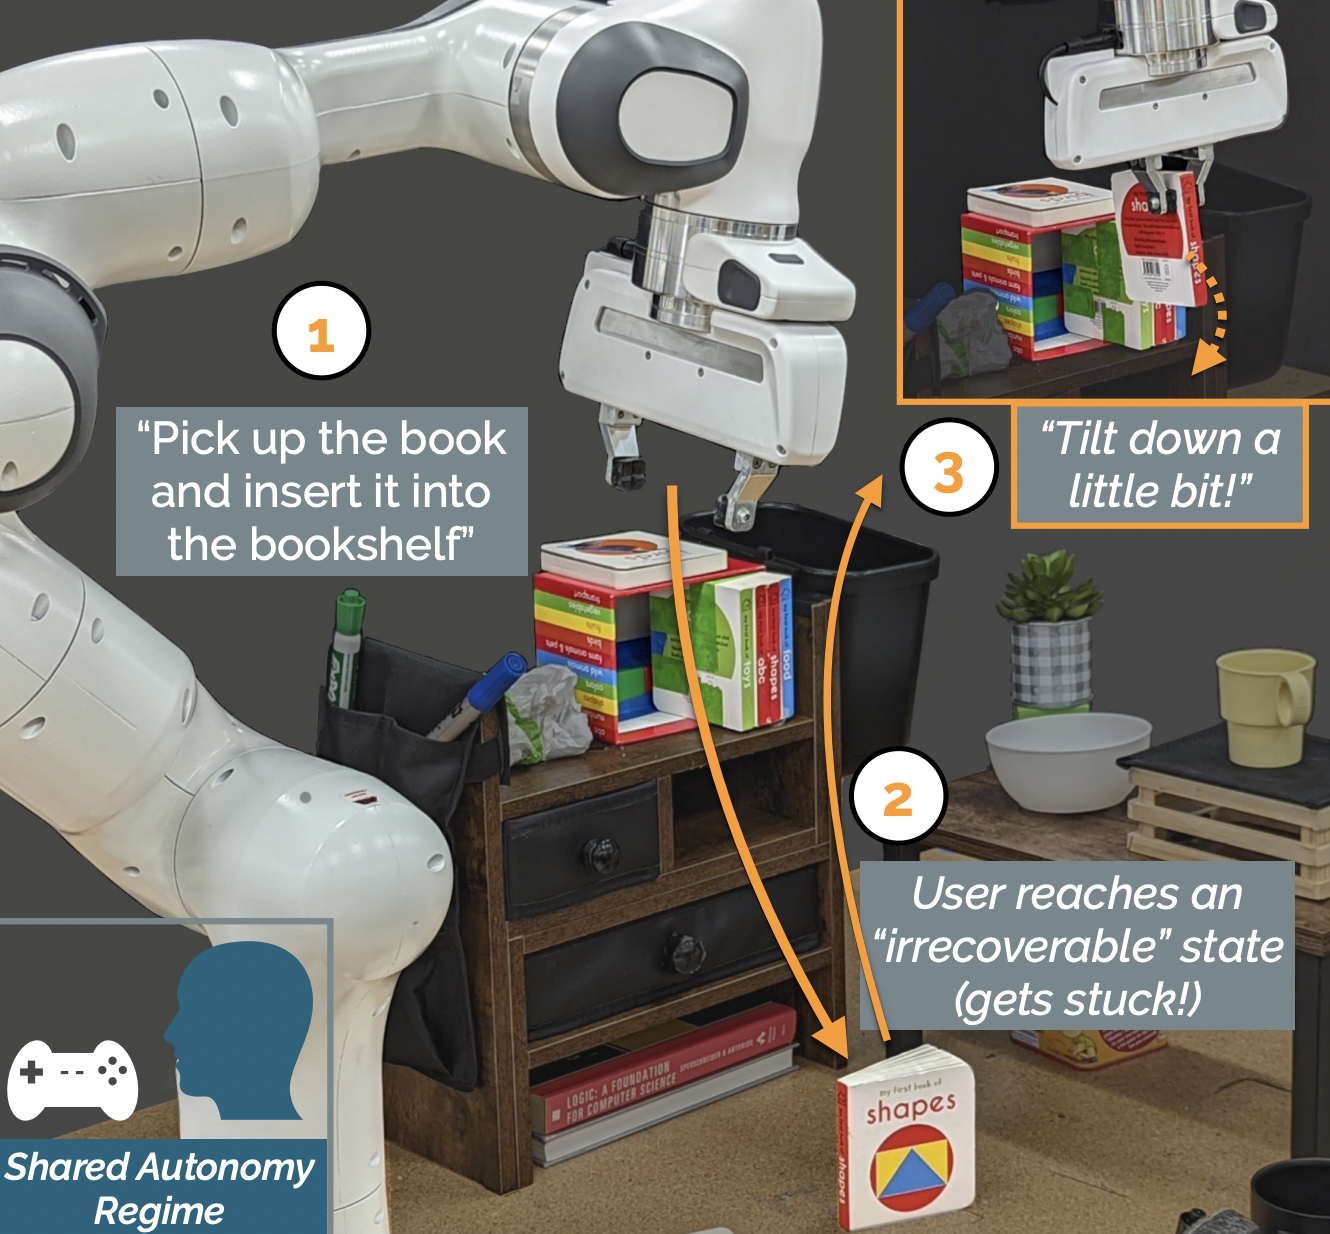
"No, to the Right" -- Online Language Corrections for Robotic Manipulation via Shared Autonomy
Yuchen Cui, Siddharth Karamcheti, Raj Palleti, Nidhya Shivakumar, Percy Liang, Dorsa Sadigh Proceedings of the 2023 ACM/IEEE International Conference on Human-Robot Interaction, 2023 arXiv LILAC: a framework for incorporating natural language corrections online during execution, enabling robots to adapt to user feedback in real-time through shared autonomy with only a handful of demonstrations. |
|
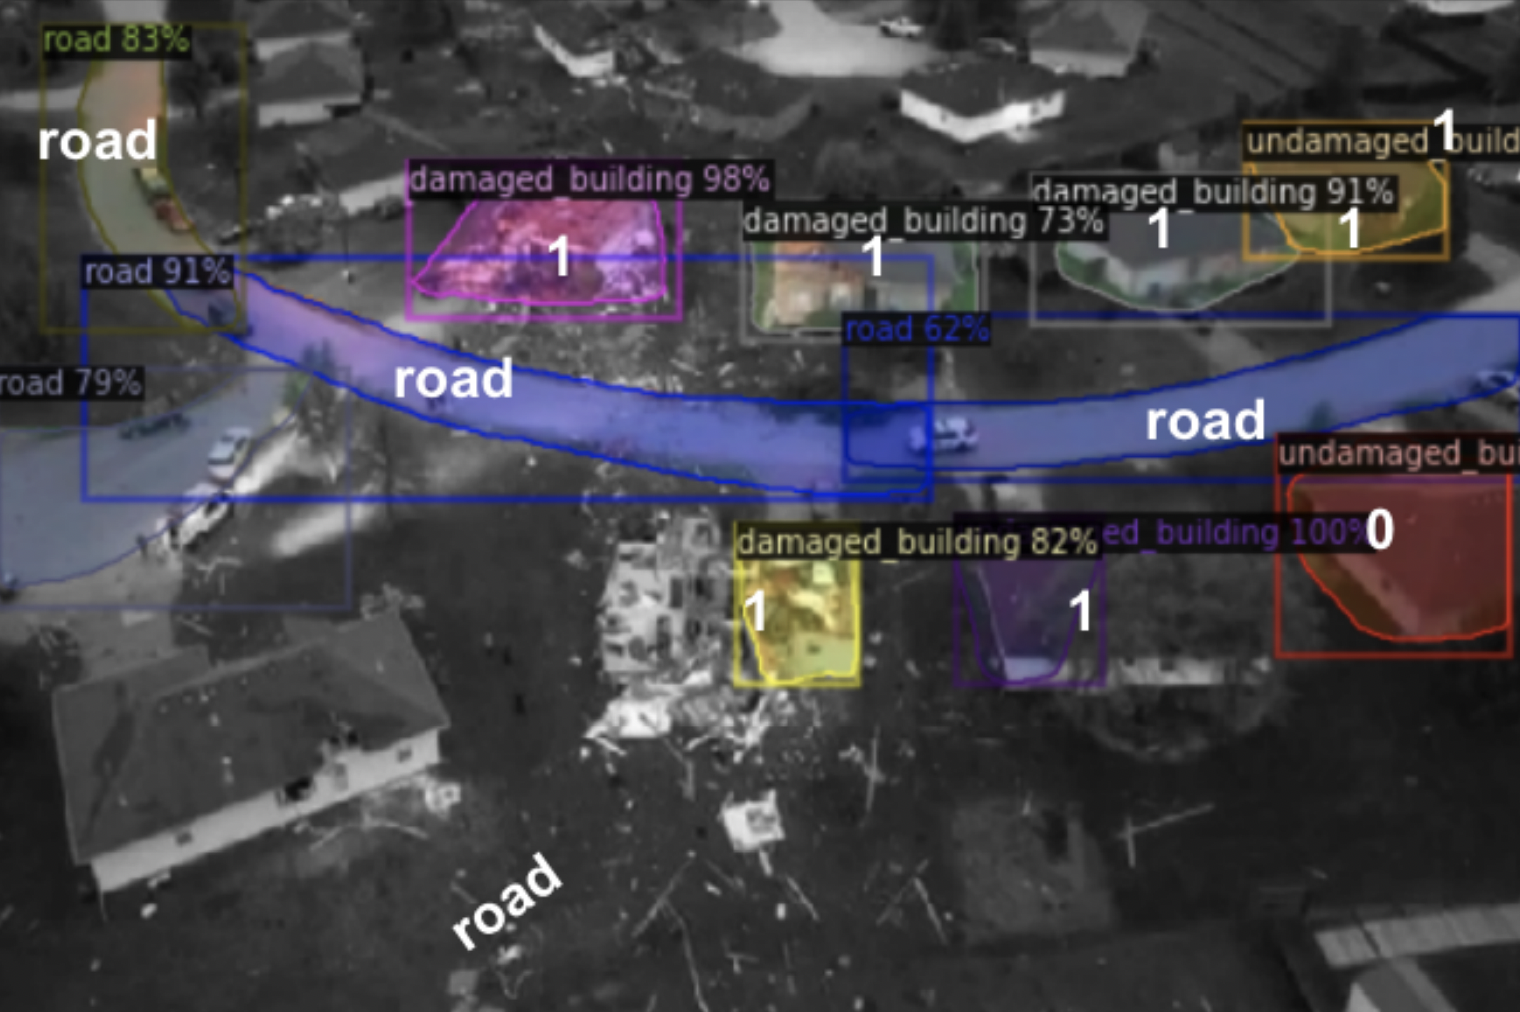
Analysis of Aerial Images Using Deep Learning to Identify Critical Areas in Natural Disasters
Nidhya Shivakumar 2022 2nd International Conference on Robotics, Automation and Artificial Intelligence, 2022 IEEE Xplore Automated disaster assessment using Faster R-CNN and Mask R-CNN on UAV imagery to identify damaged buildings and critical areas with 90% precision, reducing response times for search and rescue operations. |
|
|